FPVTune analyses Betaflight blackbox logs with a neural network and returns PID and filter settings as one-click CLI commands. It also offers free crash analysis, motor health checks and a flight time calculator, and charges only when you accept the tuning result.
Tuning a quadcopter well is the difference between a machine that tracks your inputs and one that fights them, and almost nobody does it properly.
The reason is not laziness. It is that doing it properly means reading blackbox logs — inspecting gyro noise in the frequency domain, judging step response, deciding which filters are earning their latency — and that is a genuinely technical skill most pilots never acquire.
So people copy tunes from forums, which is how a setting tuned for someone else's frame, motors and props ends up on hardware it was never meant for. FPVTune's proposition is that the log already contains the answer, and the analysis is a job a neural network can do.
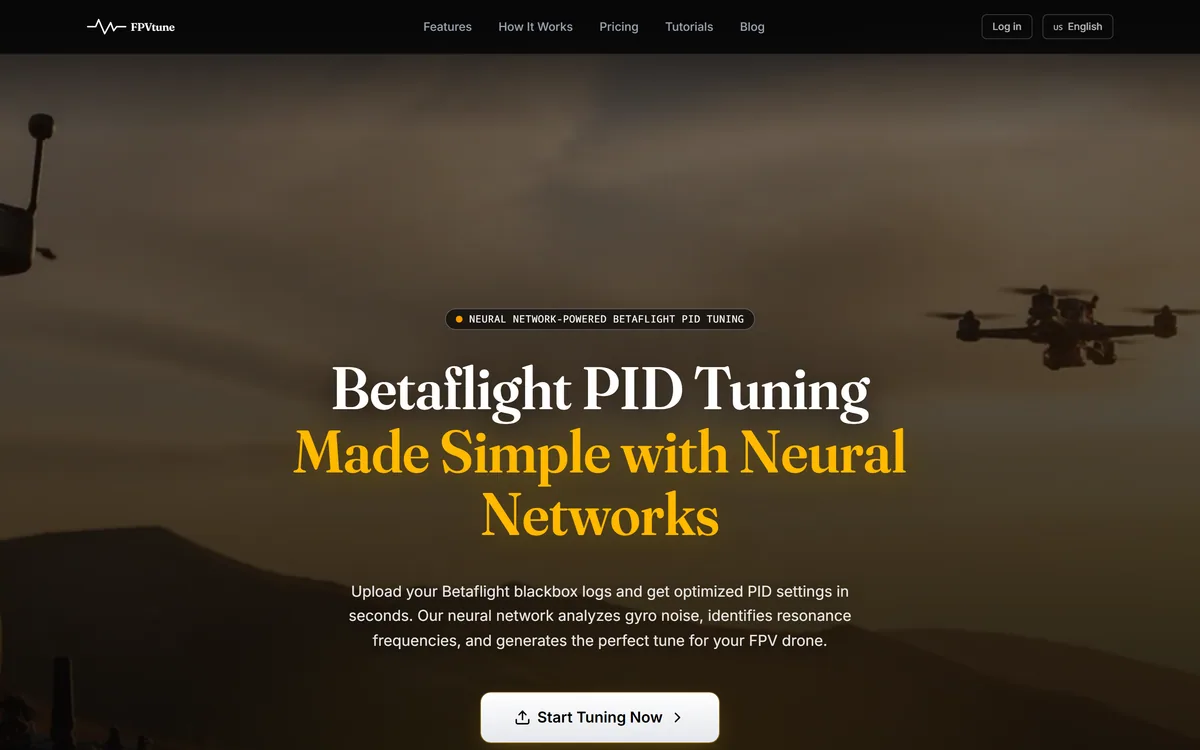
FPVTune's homepage, captured 9 September 2026, showing the blackbox analysis tools and the free utilities alongside the paid tune.
The Blackbox Tune, Summarised
It reads your actual flight data — upload a .BBL or .BFL blackbox log and a neural network returns PID and filter recommendations.
One-click CLI export, so the output is a paste-ready command set rather than a table you transcribe by hand.
Three genuinely free tools: crash analyser, motor health check and flight time calculator.
Pay only when satisfied with the analysis results — stated on the site as the commercial model for the paid tune.
Betaflight 4.5 and later, with DShot150/300/600 and bidirectional DShot, across 2-3" through 10"+ frames.
What Does A Blackbox Log Actually Tell You?
FPVTune's core service analyses Betaflight blackbox logs, and understanding what is in one explains why this is a real analysis problem rather than a lookup.
A blackbox log is high-rate telemetry from the flight controller: gyro readings before and after filtering, motor outputs, RC commands, setpoint versus achieved rate, and voltage. It is a recording of exactly what the aircraft did and what it was asked to do, several thousand times a second.
The tuning signal lives in the relationship between those channels. Oscillation shows up as periodic error between setpoint and gyro. Noise shows up in the frequency spectrum of the unfiltered gyro trace, and its frequency tells you the source — motor RPM harmonics sit in one range, frame resonance in another, propeller wash somewhere else.
That last point is why FPVTune's gyro noise spectral analysis matters more than a PID number. Filters cost latency, and latency costs responsiveness, so the goal is never maximum filtering — it is the minimum that keeps the noise out of the motors. Knowing which frequencies actually need attenuating is what separates a good filter setup from a laggy one.
This is exactly the shape of problem machine learning suits: a large, structured signal with patterns that experienced humans learn to recognise but struggle to articulate as rules. The claim is plausible on its face, which is more than most AI tooling manages.
The pattern is familiar from other domains where a model reads machine output rather than prose. Gateways like Helicone do the same for application telemetry: the data was always there, and the work is entirely in reading it.
The goal is never maximum filtering. It is the minimum filtering that keeps noise out of the motors, because every filter you add costs you latency.
Why The Free Tools Are The Smart Part
FPVTune gives away three tools — a crash analyser, a motor health check and a flight time calculator — while charging for the tune. That split is well chosen.
The crash analyser answers the question every pilot has immediately after a crash and usually cannot resolve: did something fail, or did I fly into something. A log frequently settles it. A motor that desynced, a battery that sagged, or an ESC that cut out all leave a signature, and so does the flat-line of an aircraft that was flying perfectly until it stopped.
The motor health check is the more valuable of the two in the long run. Motor thermal prediction and health analysis surface a failing bearing or a bent shaft before it takes an aircraft down, and the symptom in a log — one motor working measurably harder than its peers to hold the same attitude — is invisible from the bench.
Giving these away is good business as well as good practice. They prove the analysis works on your own data before any money is discussed, which is a far stronger argument than a testimonial.
The flight time calculator is the lightest of the three and still useful, since estimating endurance from battery capacity and current draw is arithmetic most pilots do badly or not at all.
What Can The Tune Not See?
A log-based tune is bounded by what a log records, and the gap between that and reality is where the failures live.
The biggest blind spot is mechanical. A log shows noise; it does not show that the noise comes from a props-nut that was not torqued, a bent motor bell, a cracked arm or a soft mount that has hardened with age. A tuner will filter that noise away and the aircraft will fly acceptably with a mechanical fault it is now masking.
The rule follows directly: fix the mechanics first, then tune. Filtering is not a substitute for balanced props and tight bolts, and a tune built on top of a mechanical problem becomes wrong the moment you fix it.
The second blind spot is the pilot. A log records how you flew during that flight, and a tune optimised for gentle cruising will not suit the same aircraft flown hard through a gap. Fly the log the way you intend to fly the aircraft.
The third is conditions. Temperature affects motors and batteries; wind loads the aircraft differently. A tune from a still, cold morning is not automatically the tune for a hot, gusty afternoon, though the difference is usually smaller than the previous two.
Automated analysis has this blind spot everywhere. A code scanner such as Codacy cannot see the requirement the code was meant to satisfy, and a log analyser cannot see the airframe.
Fix mechanical problems before tuning, since filters will happily mask a real fault.
Balance props and torque motor screws before recording the log you submit.
Fly the log the way you actually fly, not gently to produce a clean trace.
Record a reasonable length of varied flight rather than a short hover.
Re-tune after any hardware change — props, motors, frame or camera mass all shift the answer.
Running A Tune Properly, Start To Finish
The single most common way to waste a tuning session is to submit a log that does not contain the information the analysis needs.
Blackbox logging is off by default on many builds and has to be enabled with sufficient rate, and a hover in your garden tells the analysis very little about how the aircraft behaves under load.
Confirm you are on Betaflight 4.5 or later, since that is the supported baseline.
Check the mechanics first — prop balance, motor screws, soft mounts, arm bolts and camera mounting.
Enable blackbox logging at a sensible rate and confirm there is space on the onboard flash or card.
Fly two to three minutes of varied, representative flight: punches, hard turns, a range of throttle, and the style you actually fly.
Download the .BBL or .BFL file and upload it, starting with the free crash analyser and motor health check to sanity-check the aircraft.
Apply the exported CLI commands, save, then fly the same test again and compare the new log against the old one rather than trusting the feel.
Hardware Support And Who It Covers
FPVTune states support across Betaflight 4.5 and later, DShot150, DShot300 and DShot600 including bidirectional DShot, gyros including the MPU6000, ICM20689, ICM42688 and BMI270, and frame sizes from 2-3 inch through 10 inch and above.
That range covers effectively the whole current hobby, from tiny whoops to long-range cinelifters, and the gyro list spans several generations of flight controller hardware rather than only the newest.
Bidirectional DShot support is the detail worth noticing. It provides motor RPM telemetry back to the flight controller, which is what makes RPM filtering possible — the most effective noise-reduction technique available, because it filters exactly the frequencies the motors are producing at that instant rather than a fixed band.
A tool that understands bidirectional DShot can therefore reason about dynamic filter tuning properly, which is listed among its capabilities. On an aircraft without it, the analysis has less to work with and static filtering has to do more.
Practically, if you are running current hardware on Betaflight 4.5 or later with bidirectional DShot enabled, you are in the configuration this tool is built around.
Signal analysis follows the same shape wherever it appears — services like Deepgram extract structure from raw audio, and what comes out depends first on what went into the recording.
FPVTune: Support And Capabilities
Product type
Blackbox log analysis and PID tuning service
Paid service
AI PID tuning from uploaded logs
Free tools
Crash analyser, motor health check, flight time calculator
Analysis
Gyro noise spectral analysis, dynamic filter tuning, motor thermal prediction
Output
One-click CLI command export
Firmware
Betaflight 4.5 and later
ESC protocols
DShot150, DShot300, DShot600, including bidirectional DShot
Gyros
MPU6000, ICM20689, ICM42688, BMI270
Frame sizes
2-3 inch through 10 inch and above
Log formats
Betaflight .BBL and .BFL
Commercial model
Pay only when you are satisfied with the analysis results
Automated analysis of something humans read slowly
FPVTune free tools
The same logs
Crash cause and motor health
Diagnosing a failure before spending on a tune
Checking FPVTune Against Its Own Site
Last checked . Read from fpvtune.com, including its tools and footer pages, with the screenshot above captured in the same session.
AI PID tuning from uploaded blackbox logs confirmed as the paid service
Crash analyser, motor health check and flight time calculator all confirmed as free tools
Gyro noise spectral analysis confirmed as a stated capability
Dynamic filter tuning confirmed as a stated capability
Motor thermal prediction confirmed as a stated capability
One-click CLI export confirmed as the output format
Betaflight 4.5 and later confirmed as the supported firmware baseline
DShot150, DShot300 and DShot600 confirmed, including bidirectional DShot
Gyro support confirmed for MPU6000, ICM20689, ICM42688 and BMI270
Frame size support confirmed from 2-3 inch through 10 inch and above
Log formats confirmed as .BBL and .BFL
Commercial model stated on the site as pay only when you are satisfied with the analysis results
Footer confirmed with Privacy, Terms, Refund and Contact pages plus WhatsApp, GitHub and Twitter links
What we could not confirm: the operating company, its location or the people behind it; what the tuning actually costs, since the site states a pay-when-satisfied model without our establishing the amount; how the neural network was trained or on what volume of logs; whether uploaded logs are retained, and for how long; any independent before-and-after benchmark of tune quality; and how the satisfaction judgement is administered in practice. We did not submit a log, so nothing here reflects tested tuning output.
Editor's Verdict
4.2/5
FPVTune scores highly because it is honest about a genuinely hard problem and prices itself accordingly. Blackbox tuning is real engineering — gyro noise spectral analysis, filter shaping, thermal headroom — and the free crash analyser and motor health check give away enough for the tool to prove itself before asking for money. The pay-when-satisfied model on the paid tune is the strongest possible statement of confidence in a category full of guesswork. It is held back only by what any log-based tool cannot see: a bent motor bell, a loose arm bolt, or the flying style you are about to change. AInexfinder Editor Score: 4.2/5.
FPVTune pricing
AInexfinder does not list plan prices or billing details. For current pricing, plans, and trials, visit the official FPVTune website.
Vendor pricing, credits, and billing policies change over time. Always confirm on the official site before you buy.
Frequently asked questions
What is FPVTune?
FPVTune analyses Betaflight blackbox logs with a neural network and returns PID and filter settings as one-click CLI commands. Alongside the paid tune it offers three free tools — a crash analyser, a motor health check and a flight time calculator — and states that you pay only when you are satisfied with the analysis results.
What is in a blackbox log that makes tuning possible?
High-rate telemetry: gyro readings before and after filtering, motor outputs, RC commands, setpoint versus achieved rate, and voltage — several thousand samples a second. Oscillation shows as periodic error between setpoint and gyro; noise shows in the frequency spectrum, where the frequency identifies the source as motor harmonics, frame resonance or prop wash.
What can FPVTune not see in my log?
Mechanics, mostly. A log shows noise but not that it comes from an untorqued prop nut, a bent motor bell, a cracked arm or a hardened soft mount. Filtering will mask that fault and the aircraft will fly acceptably with a real problem hidden. Fix the mechanics first, then tune — otherwise the tune becomes wrong the moment you repair it.
Which Betaflight versions and hardware are supported?
Betaflight 4.5 and later, with DShot150, DShot300 and DShot600 including bidirectional DShot. Supported gyros include the MPU6000, ICM20689, ICM42688 and BMI270, and frame sizes run from 2-3 inch through 10 inch and above. Log files are accepted in .BBL and .BFL format.
How much does FPVTune cost?
The site states a pay-only-when-satisfied model for the analysis, but we could not establish the amount from the pages we read, nor how the satisfaction judgement is administered. The crash analyser, motor health check and flight time calculator are stated as free, so you can test the analysis on your own logs before that question arises.
Why does bidirectional DShot matter for tuning?
It sends motor RPM telemetry back to the flight controller, which is what makes RPM filtering possible — notches that track the frequencies the motors are actually producing at that instant rather than a fixed band. It is the most effective noise reduction available, and a tool that understands it can reason about dynamic filtering properly.
What flight should I record for a tune?
Two to three minutes of varied, representative flight — punches, hard turns, a range of throttle, and the style you actually fly. A gentle hover produces a gentle tune that will not suit the same aircraft flown hard through a gap, because the analysis can only optimise for what the log contains.
Can the crash analyser tell me why I crashed?
Often, yes. Motor desync, battery sag and ESC cut-outs all leave recognisable signatures in a log, as does the flat-line of an aircraft that was flying perfectly until it hit something. That distinction — failure versus pilot error — is the question every pilot has after a crash and usually cannot answer alone.
How is the motor health check useful if the motors spin fine?
Because a failing bearing or a slightly bent shaft is invisible on the bench and obvious in a log: one motor works measurably harder than its peers to hold the same attitude. Catching that before it fails in the air is worth more over a season than any single tune.
Do I still need to understand tuning if I use this?
Less than before, but the free tools are a good way to start learning. Understanding the central trade — that every filter you add costs latency, so the goal is the minimum filtering that keeps noise out of the motors — is what lets you judge whether a recommendation is sensible rather than applying it blind.
Daniel reviews AI tools the slow way — by actually using them on real projects. His reviews cover what works, what breaks, and who each tool is genuinely a good fit for.
Daniel and the AInexfinder editorial team research FPVTune using public product information, listing evidence, and (when available) hands-on checks. Scores reflect listing completeness and transparency — not paid placement.
Listings may include affiliate or sponsored placements, which are labeled when present. Editorial scores and cons are not sold. See our affiliate disclosure and review methodology.
Rodin (Hyper3D) is an AI 3D model generator that turns text prompts or a single image into detailed 3D assets, with 21 styles, generation controls, plugins for Blender, Unity and Unreal, an API and MCP, aimed at game, print, product and avatar creators.
Skybox AI by Blockade Labs generates 360-degree equirectangular panoramas and skyboxes with stated generation times as fast as 15 seconds, 32-bit HDRI export for scene lighting, a Unity plugin, MCP support and direct export to Blender and Unreal.
Instead is an AI agent platform for tax work spanning research across 1,500+ authoritative sources, document extraction from K-1s, W-2s and 1099s, multi-entity planning, and e-filing with the IRS, 48 states and cities across all five entity types. The platform is free, with agent work charged per credit.
Layla builds day-by-day itineraries from your dates, budget and travel style using live pricing and availability for flights, hotels, trains and activities. Human travel experts can take over at any stage to plan, book and manage the trip end to end. Layla AI GmbH is based in Berlin.
Decory is a free mobile AI interior design app that redesigns a room from a photo in about 30 seconds across 15+ styles. It also replaces and removes objects, previews flooring and wall colours, and searches furniture. Operated by The AI Journey Inc., with 500,000+ downloads claimed.
Tamarind Bio is a cloud platform that puts the state of the art in computational biology, AlphaFold, RFdiffusion, ProteinMPNN, GROMACS and over a hundred more tools, behind one web interface and API, so scientists can design antibodies, peptides, enzymes and small molecules without deploying anything.